Datawhale-EAI · AMD Radeon + ROCm
AMD Physical AI for embodied household manipulation
A complete workflow from data and training to closed-loop evaluation, anchored by the RoboCasa365 household benchmark and extended through DexJoCo dexterity, DISCOVERSE simulation, and PAC-MAN whole-body safety control.
RoboCasa365 Household
DexJoCo Dexterity
DISCOVERSE Simulation
PAC-MAN Safety
Household RoboCasa365
Dexterous DexJoCo
Simulation DISCOVERSE · 3DGS
Safety PAC-MAN
00 / FLAGSHIP
RoboCasa365 official policies on AMD
Official Pi0.5 and GR00T checkpoints complete the same 16-task closed-loop evaluation on the AMD Ryzen AI MAX+ 395. Each model runs 800 formal episodes with per-task results and synchronized four-view video.
PRIMARY SHOWCASE · 4:59 · ENGLISH
AMD Physical AI in motion
From DexJoCo dexterous manipulation and RoboCasa365 household tasks to DISCOVERSE multi-view replay and PAC-MAN safety control, the film shows one AMD workflow across multiple robot capabilities.
DexJoCo · Pi0.5 · JAX 0.10DexJoCo dexterous-hand success
DISCOVERSE · AMD · 3-viewHD cabinet-door replay
01 / PROJECTS
Seven complementary evidence tracks
From a teaching baseline to multi-simulator, benchmark, creative-operation, and hardware evidence.
verified result
RoboCasa365 · 16 tasks
Official Pi0.5 and GR00T checkpoints run the same 16-task, 50-episode closed-loop protocol on the AMD 395 with per-task statistics and four-view video.
- tasks
- 16
- episodes
- 50 / task
- video
- 4-view
migration complete
DISCOVERSE · full-stack migration
Official scenes, expert trajectories, policy entry points, closed-loop evaluation, HD multi-view replay, and MP4 export form a complete migration path from simulation to visual evidence.
- Runtime
- 18 / 18
- AIRBOT
- 12 / 12
- Expert data
- 500 eps
three dodge modes
PAC-MAN · perceptive CBF-RL
The upstream dodge_link_cbf ONNX policy fuses four depth-history frames with G1 proprioception. The robot holds its stance, then autonomously selects a duck, left sidestep, or right sidestep when the ball enters view.
- observation
- 960-D
- modes
- 3 / 3
- video
- 1080p
multi-task evaluated
DexJoCo · Pi0.5 native JAX
Official Orbax weights run natively with AMD ROCm JAX 0.10 across bimanual coordination, tool use, precision grasping, and long-horizon contact tasks, creating a multi-task Pi0.5 dexterous-manipulation showcase.
- tasks
- 11
- runtime
- JAX 0.10
- media
- 10+ videos
device setup
AMD dual-device lab
The local Ryzen AI MAX+ 395 runs sustained evaluation while the cloud Radeon Pro W7900 handles high-memory training and migration validation.
- AMD 395
- RoboCasa
- W7900
- VLA + ACT
- stack
- PyTorch + JAX
Public result JSON, training checkpoints, HD video, and reproduction guides are indexed by workstream.
02 / BENCHMARK
RoboCasa365 matched task benchmark
GR00T 28.75%
Pi0.5 17.75%
GR00T N1.5 · official 120k
230 / 800
Pi0.5 · official 75k
142 / 800
| Task | GR00T | Pi0.5 | Delta |
|---|---|---|---|
| Loading verified results… | |||
02B / LONG-HORIZON SHOWCASE
GR00T long-horizon success showcase
GR00T N1.5 multi-task weights on the AMD 395 complete restocking and meal-packing sequences in household scenes, with four synchronized camera views for every trace.
RestockBowls · 10 episodes
successRestock task · successful trace
PackIdenticalLunches · 10 episodes
successMeal-packing task · successful trace
Four synchronized views reveal robot motion, wrist detail, and environment state throughout each long-horizon household task.
02C / DISCOVERSE SHOWCASE
DISCOVERSE HD three-view replay
The same AMD-migrated MMK2 expert state machine; each showcase includes native 1920×1080 cam_0, cam_1, and cam_2 recordings composed into one three-view canvas.
4official tasks
12native camera recordings
1920×1080each native view · 20/25 fps
View results and SHA
DISCOVERSE · MMK2 · 3-view · 1920×1080
successBox pick · strict success
DISCOVERSE · MMK2 · 3-view · 1920×1080
successDrawer open · strict success
DISCOVERSE · MMK2 · 3-view · 1920×1080
successCabinet door open · strict success
DISCOVERSE · MMK2 · 3-view · 1920×1080
successCup to plate · strict success
Three synchronized views capture the workspace, end-effector detail, and environment state on one replay timeline.
02D / 3DGS RENDERER
Real Gaussian Splatting rendering on ROCm
The ROCm Gaussian renderer combines point assets, camera motion, lighting, and robot replay into a visual layer for the migrated scenes.
2ROCm renderer targets
2.36Mloaded Gaussian points
640×360non-empty validation frames
View evidence and SHA
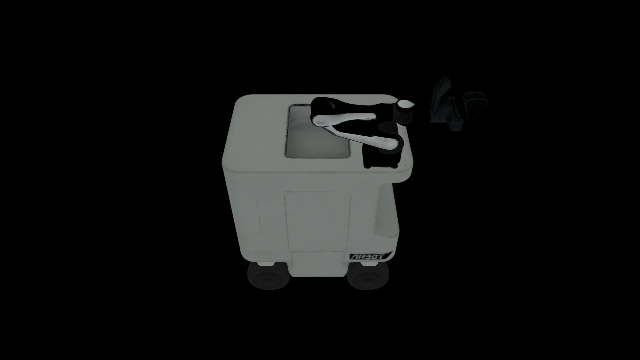
GSRendererMuJoCo · ROCmRM2 · 1,334,537 points
640×360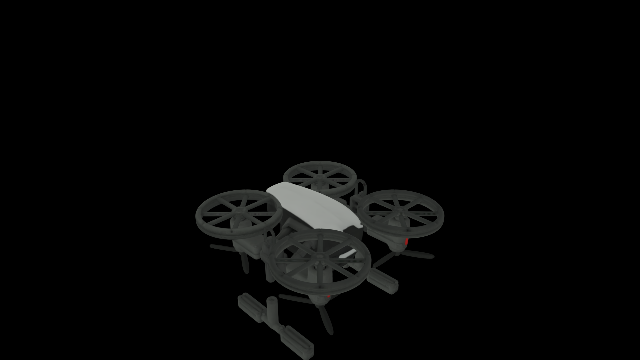
GSRendererMuJoCo · ROCmSkyRover · 1,026,855 points
640×360DYNAMIC EVIDENCE
20 fps · 4 s · native videoDynamic replay: Franka and UR5e
3DGS example · FrankaROCm renderer replay
3DGS example · UR5eROCm renderer replay
Two renderer targets, two non-empty validation frames, and two dynamic films demonstrate the ROCm Gaussian Splatting path; the DISCOVERSE expert films connect rendering to robot task execution.
03 / SUCCESS EVIDENCE
Success cases
DexJoCo · Pi0.5 native JAX 0.10 · task replay
successwater_plant · seed 0 success
RoboWits · ACT 100k · W7900 · ego view
success06_dominos · episode 1 success · 848×480
PAC-MAN · Unitree G1 · upstream ONNX · free-base
3 dodge modesIn-place whole-body dodging
Every Embodied · SmolVLA
successRed-cup strict success
RoboCasa365 · GR00T · 4-view showcase
successCloseFridge success · 1920×1080
RoboCasa365 · Pi0.5
successDrawerToCounter success
DISCOVERSE · Expert
successBlock bridge · strict replay
03 / DEXJOCO MULTI-TASK
11 tasks
Pi0.5 success case archive
Official multi-task weights run on AMD ROCm JAX 0.10 across 11 dexterous manipulation tasks. The page presents task videos covering bimanual coordination, tool use, precision grasping, and long-horizon contact, with the complete task map and result JSON archived alongside them.
Official multi-task suite11 tasks
Bimanual coordination, tool use, precision grasping, and long-contact tasks form the complete task family.
AMD runtimeJAX 0.10
Official Orbax weights run natively on AMD ROCm, with video and JSON produced by one evaluation entry point.
Task media archive10 success traces
The gallery presents bimanual motion, precision contact, tool use, and deterministic success-seed replays.
| Task | Capability | Task media |
|---|---|---|
| bimanual_assembly | two-hand assembly | View task |
| bimanual_hanoi | long-horizon placement | View task |
| bimanual_microwave_cook | tool + contact coordination | View task |
| bimanual_photograph | precision pose control | View task |
| click_mouse | fine manipulation | View official demo |
| fold_glasses | deformable object handling | View official demo |
| hammer_nail | tool use | View official demo |
| pick_bucket | grasp and lift | View official demo |
| pinch_tongs | precision pinch | View official demo |
| water_plant | pouring and release | View task |
TASK VIDEO ARCHIVE
official demos + task tracesBimanual coordination, tool use, and precision grasping
official · seed 0click_mouse
official · seed 0fold_glasses
official · seed 0hammer_nail
official · seed 0pick_bucket
official · seed 0pinch_tongs
success seed 3bimanual_assembly
success seed 4bimanual_hanoi
success seed 1bimanual_microwave_cook
success seed 3bimanual_photograph
success seed 2water_plant
04 / PIPELINE
One auditable loop
- 01SimulationRoboCasa · MuJoCo · DISCOVERSE
- 02Datafixed seed · LeRobot · audit
- 03AMD trainingSmolVLA · Pi0.5 · GR00T · ACT
- 04Closed-loop evaldenominator · success/failure videos
- 05EvidenceJSON · SHA256 · checkpoint
05 / TRAINING
Training
The public tutorial provides runnable notebooks, protected weights, configs, strict evaluation summaries, and SHA256 records.
Six end-to-end notebooksSmolVLA / Pi0 / ACT, ordinary and protected training
SmolVLA protected checkpoint57/60 formal result, configuration, video, and SHA
Pi0 advanced checkpoint12/14 strict · unseen 9/10
ACT training checkpointTraining logs, action policy, and physical replay
RoboWits checkpoint archiveW7900 100k model and intermediate checkpoints
Public integrity manifestSHA-256 for representative media and result JSON
AMD migration detailsgates, hard cases, boundaries, and the DexJoCo JAX route
99 / FAILURE CASES
Failure cases
Boundary-case replays expose policy behavior across navigation, approach, contact, grasp, and placement with synchronized visual evidence.
RoboCasa365 · GR00T · 4-view showcase
failureCloseFridge failure
RoboCasa365 · Pi0.5
failureDrawerToCounter failure
DISCOVERSE · Pi0.5 diagnostic
failureClosed-loop policy failure
Every Embodied · SmolVLA
failure